
HuanYu Intelligent Transportation has launched an 8-camera autonomous driving perception solution.
Time:
2021-07-21 16:05
The "iCar Smart Vehicle Exhibition" (the 7th China Shanghai Intelligent Connected Vehicle Exhibition 2021) opened at the Shanghai New International Expo Center from July 14 to 16, 2021! Huanyu Zhixing was invited to participate in the exhibition, launching the 8-camera autonomous driving perception solution (Athena 5.0) first. The TITAN series (L3+) and PALLAS series (L2+) domain control products equipped with this solution were showcased on-site.
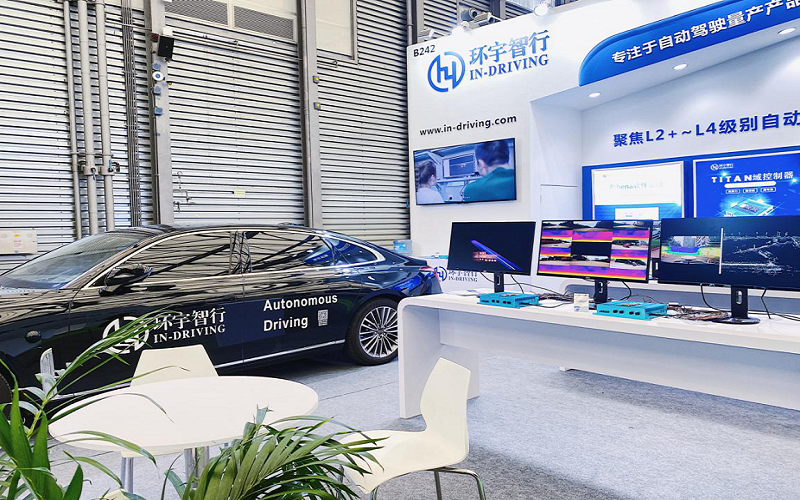
Currently, the TITAN and PALLAS are equipped with a full visual perception solution, which has been adapted to models such as the Hongqi H9, and large-scale real vehicle testing and verification are being conducted in Wuhan and Suzhou.
The full visual autonomous driving solution launched by Huanyu Zhixing adopts layered temporal network technology, with 8 cameras sharing a backbone network. Under the backbone network, 64 terminal tasks are designed, including detection, segmentation, stitching, tracking, depth estimation, 3D detection, scene memory, 3D reconstruction, prediction, driving behavior analysis, and hazardous scene diagnosis. The entire network system has a synchronized design for inference task results during real vehicle deployment. This means that while the system is running, 128 terminal tasks are operating simultaneously, with a total processing cycle of less than 50ms. This solution has been implemented through distributed deployment across multiple TITAN series controllers. In the future, this design will be deployed on Areas chips to achieve All in One domestic delivery.
In terms of timing, we retained historical information for 2 seconds and predicted for 8 seconds, truly achieving real-time memory and prediction. In addition to abandoning high-precision maps, we use real-time constructed relative maps (not relying on external high-precision map data, only navigation map data, and not relying on high-precision positioning). We use dynamic SLAM technology for obstacle motion estimation, with speed measurement accuracy within 2 km/h (compared to LiDAR and millimeter-wave).
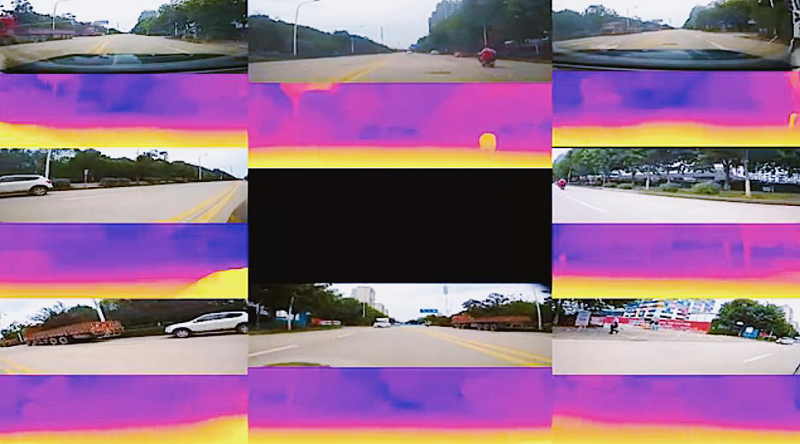
Huanyu Zhixing has accumulated data over 2 years between Suzhou and Wuhan on highways and urban areas, covering common rainy and foggy weather as well as some extreme weather conditions like heavy rain and snow. In typical scenarios such as tunnels, construction sites, and elevated roads, the full visual solution has achieved performance close to that of high-resolution LiDAR.
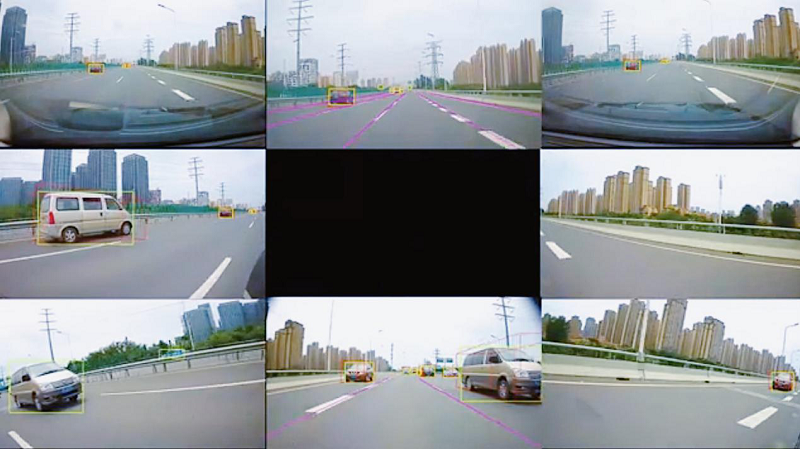
In terms of hardware, we use Huanyu Zhixing's self-developed L3/L4 level autonomous driving controller TITAN series and L2~L2+ level autonomous driving controller PALLAS, which feature high reliability, high performance, high computing power, and high integration. They are currently applied in various scenarios such as low-speed L4 campus vehicles, low-speed unmanned delivery vehicles, L2/L2+ highway autonomous driving, and automatic parking.


Contact Us
Business cooperation: Manager Deng 86-137 1437 6082
Media Cooperation: Cold Manager 86-136 5242 6616
Company address: Wuhan Economic and Technological Development Zone 201M plot of the Chinese Huihe Science and Technology Park(Huazhong Zhigu) Phase I D4D5 R & D Building, Room 3, Floor 3

Official WeChat Public Number
After-sales support
Pre-Sales Support
Copyright © en.in-driving.com All Rights Reserved | Powered by www.300.cn